Whole-Body Tactile Navigation VIP
Georgia Tech · Team Member
Developing introductory experience with tactile sensing, robotic navigation, simulation, Python, control, and mechanical design.
Third-year Mechanical Engineering student concentrating in Robotics and Automation. Interested in product design engineering, mechanical design, and the future of automation.
Design, fabrication, and technical development.
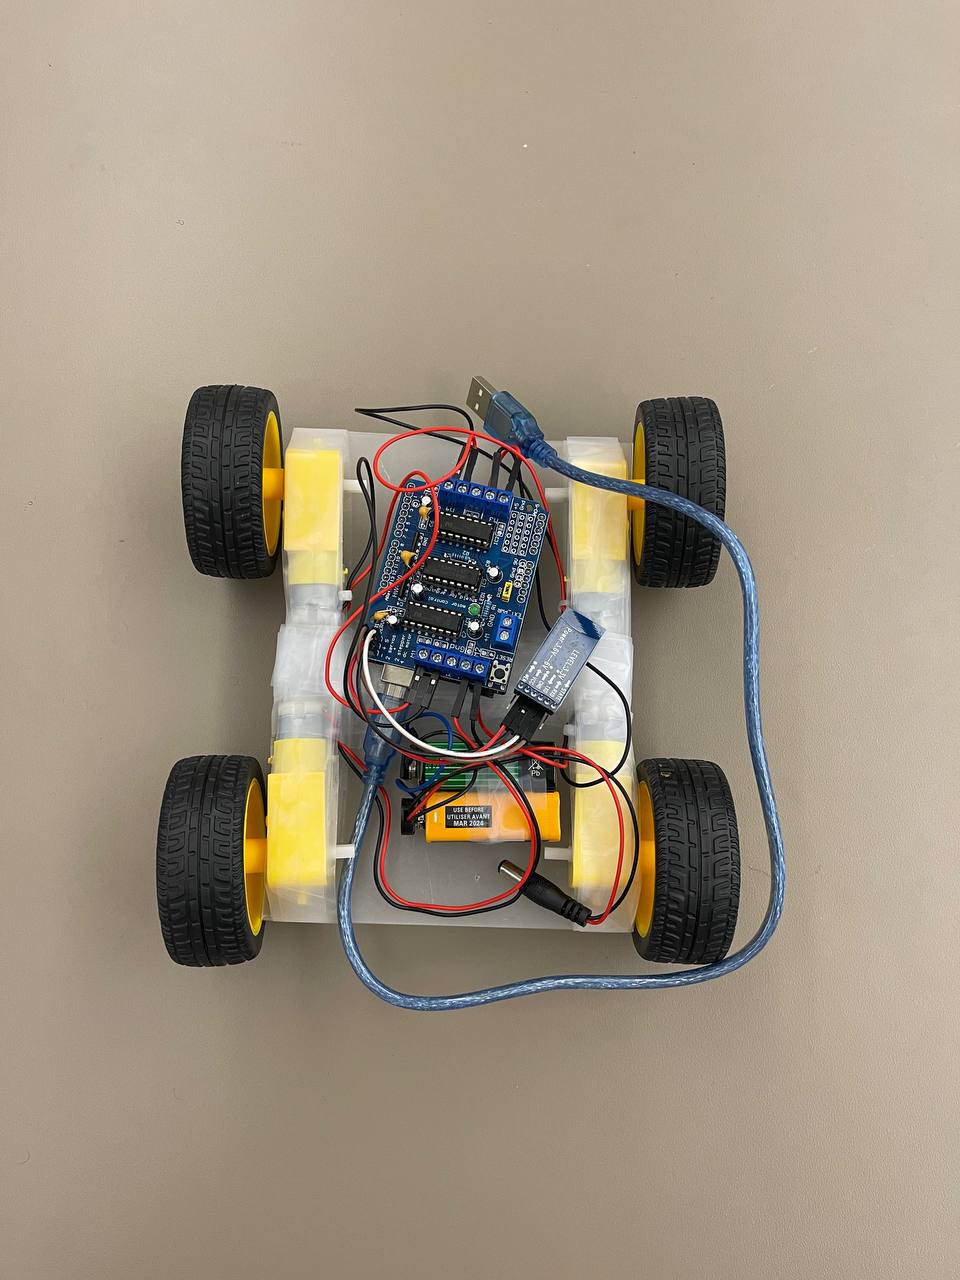
Developing a two-wheel differential-drive robot for camera-based object detection and autonomous target approach.
Fabric sourcing platform developed for the Perimeter College Innovation Challenge.
Developing introductory experience with tactile sensing, robotic navigation, simulation, Python, control, and mechanical design.
Working with vehicle structures, CAD, manufacturing, and collaborative engineering.