May 2026 — Present
Autonomous Object-Finding Mobile Robot
A two-wheel differential-drive robot designed for camera-based object detection and autonomous target approach.
Project
Developing the system architecture and SolidWorks layout for the robot.
Selecting and integrating the drivetrain, sensors, electronics, and power system around a Raspberry Pi and ESP32 control architecture.
Upcoming Upgrades
The next version adds camera-based object detection and autonomous target approach.
Planned work includes a Raspberry Pi and ESP32 control architecture, updated drivetrain and power integration, sensor mounting, and a revised SolidWorks layout.
Earlier RC-Car Prototype
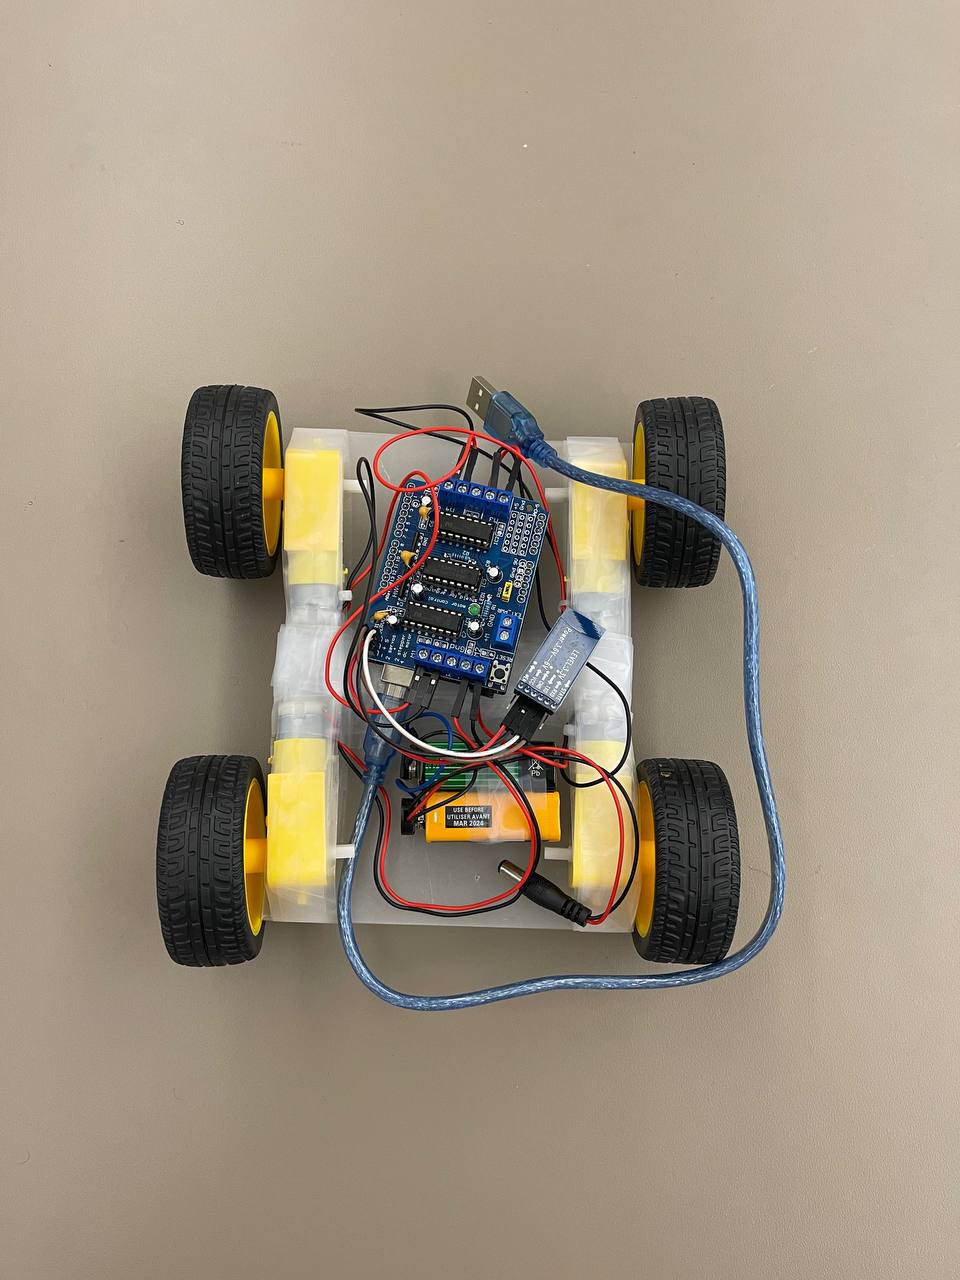
The earlier build used Arduino programming, Bluetooth control, motor control, electronics integration, and mechanical assembly.